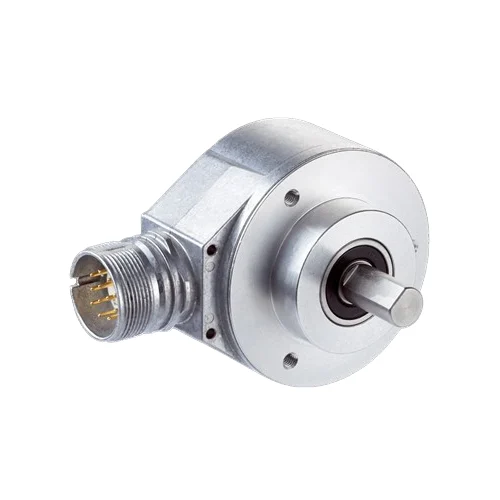
SICK 1036681 DFS60E-S4AA01024 TTL Incremental Encoder

USD 390.26

DFS60E-S4AA01024 provides 1,024 pulses per revolution, six-channel TTL/RS-422, a 10 mm solid shaft, face-mount flange and radial M23 12-pin connector.

SKU SICK-1036681 Category
SICK Encoders

SICK DFS60E-S4AA01024 TTL Incremental Encoder

BrandSICK
Model IdentifierDFS60E-S4AA01024
Official Part Number1036681

Technical Overview

The SICK DFS60E-S4AA01024 is an incremental encoder with 1,024 pulses per revolution and six-channel TTL/RS-422 output. Its 10 mm solid stainless-steel shaft has a flat and 19 mm length, with a face-mount flange for mechanical installation. The 4.5–5.5 V interface provides A, B and reference signals with complementary channels, allowing external electronics to evaluate rotational movement and direction. Output frequency is no more than 300 kHz and operating speed is up to 9,000 rpm, with thermal design allowing for 3.3 K self-heating per 1,000 rpm. A radial M23 twelve-pin connector and aluminum-diecast housing support connection, with IP67 housing/connector protection when the mating connector is fitted and IP65 at the shaft.

1,024-pulse TTL/RS-422 incremental encoder with 10 mm solid shaft, face-mount flange, 4.5–5.5 V supply and radial M23 twelve-pin connector.

Key Features

  • 1,024 pulses per revolution
  • Incremental six-channel TTL/RS-422 interface
  • A, B and Z reference signals with complementary channels
  • 4.5–5.5 V supply; 40 mA current consumption without load
  • Output frequency ≤300 kHz; load current ≤30 mA
  • 10 mm solid stainless-steel shaft with flat; 19 mm shaft length
  • Face-mount flange; aluminum-diecast housing
  • Radial M23 twelve-pin male connector
  • Operating speed ≤9,000 rpm; self-heating allowance 3.3 K per 1,000 rpm
  • IP67 housing/connector with mating connector fitted; IP65 shaft side

Provide rotational movement, direction and reference feedback through six TTL/RS-422 channels from a 10 mm solid-shaft encoder.

Technical Specification Matrix

ParameterValue
Functional principleIncremental rotary encoder
Pulses per revolution1,024; observe maximum revolution range
InterfaceTTL / RS-422, 6-channel incremental
SignalsA, complementary A, B, complementary B, Z and complementary Z
Measuring step90° electrical / pulses per revolution
Measuring-step deviation±0.15° at binary number of lines
Error limits±0.3°
Reference signal1; 90° electrical, logically gated with A and B
Output frequency≤300 kHz
Load current≤30 mA
Operating current40 mA without load
Initialization time40 ms
Power supply4.5–5.5 V
Output short-circuit protectionShort circuit to another channel, supply or GND permissible for max. 30 s
ConnectionMale connector M23, 12-pin, radial
Mechanical designSolid shaft, face-mount flange
Shaft diameter10 mm, with flat
Shaft length19 mm
Shaft materialStainless steel
Flange materialAluminum
Housing materialAluminum diecast
Startup torque0.5 Ncm at +20 °C
Operating torque0.3 Ncm at +20 °C
Permissible shaft loading80 N radial; 40 N axial
Operating speed≤9,000 rpm
Self-heating allowance3.3 K per 1,000 rpm when designing the operating temperature range
Rotor moment of inertia6.2 gcm²
Bearing lifetime3.6 × 10^10 revolutions
Angular acceleration≤500,000 rad/s²
IP ratingIP67 housing side and male connector with mating connector fitted; IP65 shaft side (IEC 60529)
Operating temperature0 to +85 °C; account for speed-related self-heating
Storage temperature−40 to +100 °C without package
Relative humidity90%, condensation not permitted
Shock resistance50 g for 6 ms, EN 60068-2-27
Vibration resistance20 g, 10–2,000 Hz, EN 60068-2-6
Electromagnetic compatibilityEN 61000-6-2 and EN 61000-6-3
MTTFD300 years, EN ISO 13849-1; nominal component loading, average ambient +40 °C, 8,760 h/year; all electronic failures treated as hazardous; standard product, not a safety component
M23 signal assignmentPin 6=A̅; 5=A; 1=B̅; 8=B; 4=Z̅; 3=Z; 10=GND; 12=Us; pins 2/9/11 unassigned
Shield connectionScreen connected to encoder housing; connect to ground at control side
Physical Weight (kg)0.3

Industrial Applications

1. Measuring conveyor-drive speed

A conveyor drive can couple the encoder shaft to a rotating drive element and send TTL/RS-422 pulses to a compatible counter input. The controller evaluates pulse frequency to calculate rotational speed using the specified 1,024 pulses per revolution. The six-channel incremental interface carries the movement signals through the radial M23 connection.

Problem Solved

Pulse-based rotational feedback helps the controller follow drive speed during production, supporting coordinated conveyor operation without estimating motion solely from the motor command signal.

1,024 pulses/rev TTL/RS-422 Speed feedback

2. Following a material feed length

A material-feed mechanism can connect the encoder to a calibrated measuring wheel or feed shaft so rotation represents material travel. The A and B incremental signals allow compatible electronics to accumulate movement and determine direction. Known wheel circumference or transmission ratio then converts the pulse count into feed length for a cutting or dispensing sequence.

Problem Solved

Accumulated motion pulses provide a feed-length value for the controller, helping coordinate cut or dispense positions using measured movement rather than relying only on elapsed operating time.

Incremental A/B 1,024 pulses/rev Feed length

3. Referencing an indexing mechanism

An indexing mechanism can couple the solid shaft to its rotary axis and evaluate incremental movement between machine positions. The reference signal, logically gated with A and B, provides a repeatable rotational reference for compatible control electronics. After establishing the machine reference, the controller tracks subsequent motion through the incremental pulse channels.

Problem Solved

A reference event and incremental movement feedback help the controller coordinate repeated indexing cycles while retaining a defined rotational starting reference for subsequent position calculations.

Reference signal Face-mount flange Incremental feedback

Select your currency