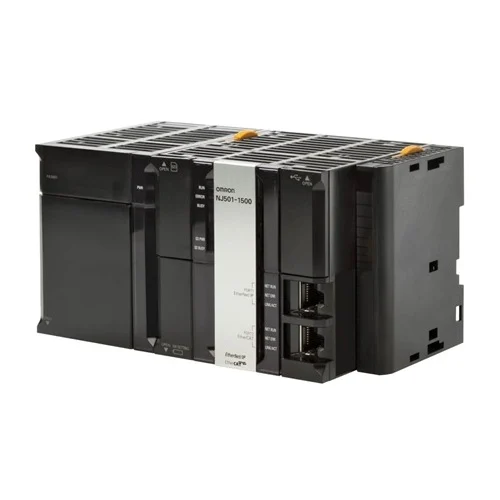
Omron NJ501-4400 PLC CPU Module

USD 14,970.56

Robot-capable PLC CPU with 20 MB program memory, built-in EtherCAT/EtherNet/IP, 32 axes, 8 robots, 0.5 ms cycle time.

SKU Omron-NJ501-4400 Category
Top Brands > Omron > PLC CPU Modules

Omron NJ501-4400 PLC CPU Module

Model Identifier NJ501-4400
Official Part Number NJ501-4400
GTIN Standard NA

Technical Overview

NJ501-4400 is an Omron Sysmac NJ5 robotics CPU unit / PLC CPU module with built-in EtherCAT and EtherNet/IP, 20 MB program memory, 6 MB variable memory, support for up to 32 synchronous axes and up to 8 robots, and a primary task cycle time of 0.5 ms. It is positioned as a machine automation controller for high-speed motion, sequence control, and robot kinematics in industrial automation systems.

Key Features

  • Built-in EtherCAT Master for motion control networking
  • Built-in EtherNet/IP communication
  • Supports motion control, robotics, and sequence control
  • Up to 32 synchronous axes
  • Up to 8 robots
  • 20 MB program memory
  • 6 MB variable memory
  • Primary task cycle time of 0.5 ms
  • USB programming connection
  • DIN rail mounting

Integrated robotics CPU with 32-axis motion and up to 8 robot control in one controller.

Technical Specification Matrix

ParameterValue
Controller functionalityMotion control, Robotics, Sequence control
Max. number of synchronous axes32
Max. number of axes (incl. virtual)32
Max. number of robots8
Primary task cycle time0.5 ms
Program memory20 MB
Variables memory6 MB
Communication port(s)EtherCAT Master, EtherNet/IP, USB
Communication option(s)CAN, CompoNet Master, DeviceNet Master, DeviceNet Slave, EtherCAT Slave, MODBUS Master, MODBUS Slave, PROFIBUS DP Master, PROFIBUS DP Slave, PROFINET Master, Serial RS-232C, Serial RS-422, Serial RS-485
MountingDIN rail
Special functionDelta Robot Control

Industrial Applications

1. High-speed robotic packaging cell control

The 0.5 ms task cycle, 32-axis synchronization, and support for up to 8 robots make it suitable for coordinated pick-and-place and packing lines.

Problem Solved

Coordinates multiple robots and servo axes with deterministic timing to prevent throughput loss and motion desynchronization.

0.5 ms cycle time32 axes8 robotsEtherCATrobot kinematics

2. Multi-station assembly machine control

The controller can manage sequence logic plus synchronized motion for complex assembly machines with multiple coordinated stations.

Problem Solved

Replaces fragmented PLC and motion controller architectures with one unit that handles sequencing and motion together.

sequence controlmotion controlEtherNet/IPEtherCAT MasterDIN rail

3. Delta robot end-of-line handling system

The explicit delta robot control function and robot-capable architecture fit fast sorting, case loading, and end-of-line handling cells.

Problem Solved

Provides native robot coordination for delta mechanisms without needing a separate robot controller.

Delta Robot Controlroboticshigh-speed processingsequence controlmachine automation controller
Select your currency