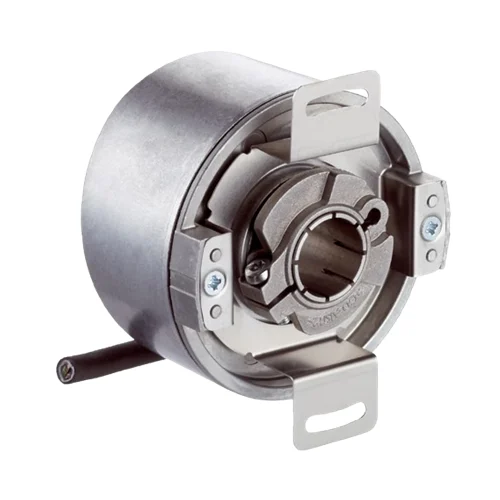
SICK 1056773 DFS60B-TDEK00512 HTL Incremental Encoder

USD 587.08

DFS60B-TDEK00512 provides 512 PPR, HTL / push-pull signals, 10 mm through hollow shaft, 10–32 V supply and a 1.5 m eight-wire cable.

SKU SICK-1056773 Category
SICK Encoders

SICK DFS60B-TDEK00512 HTL Incremental Encoder

BrandSICK
Model IdentifierDFS60B-TDEK00512
Official Part Number1056773

Technical Overview

The SICK DFS60B-TDEK00512 is a 512-pulse-per-revolution incremental encoder with a 10 mm through hollow shaft with front clamp. Six HTL / push-pull signal channels provide A, B and Z signals with their complements, allowing external counting and frequency inputs to evaluate rotation. One reference signal is 90° electrical and logically gated with A and B. The device uses a 1.5 m eight-wire universal cable and a 10–32 V supply. Its stainless steel shaft, aluminum flange and die-cast aluminum housing provide IP65 on housing and shaft sides. Mechanical speed is rated to 6,000 rpm, with a 3.3 K per 1,000 rpm self-heating allowance when designing the operating temperature range.

512 PPR HTL / push-pull incremental encoder with 10 mm through hollow shaft with front clamp, 10–32 V supply and 1.5 m eight-wire universal cable.

Key Features

  • DFS60B-TDEK00512 / 1056773: 512 pulses per revolution
  • 10 mm through hollow shaft with front clamp
  • Six HTL / push-pull channels: A/B/Z and complementary signals
  • One 90° electrical reference signal, logically gated with A and B
  • ≤600 kHz output frequency; 40 ms initialization; ≤30 mA load current
  • 10–32 V supply; ≤0.5 W consumption without load
  • 1.5 m eight-wire universal cable
  • ≤6,000 rpm mechanical rating; 3.3 K per 1,000 rpm self-heating allowance
  • Stainless steel shaft; aluminum flange; die-cast aluminum housing
  • IP65 on housing and shaft sides; 70 g / 6 ms shock resistance

Provide A/B rotation feedback and a separate revolution reference to external machine control through three complementary incremental signal pairs.

Technical Specification Matrix

ParameterValue
Functional principleIncremental rotary encoder
Pulses per revolution512; observe the manufacturer speed/frequency limits
Measuring step90° electrical / pulses per revolution
Measuring-step deviation±0.008° for this binary pulse count
Error limits±0.05°
Electrical interfaceHTL / push-pull
Signal channelsSix: A, complement A, B, complement B, Z and complement Z
Reference signalOne Z reference per revolution; 90° electrical, logically gated with A and B
Initialization time40 ms
Output frequency≤600 kHz; operating speed also limited by the selected pulse count and mechanical rating
Load current≤30 mA
Power supply10–32 V
Connection1.5 m eight-wire universal cable
Mechanical design10 mm through hollow shaft with front clamp
Shaft diameter10 mm F7 hollow-shaft bore
Shaft materialStainless steel
Flange materialAluminum
Housing materialDie-cast aluminum
Start-up torque0.8 Ncm at +20 °C
Operating torque0.6 Ncm at +20 °C
Operating speed≤6,000 rpm; observe output-frequency limit and speed-dependent self-heating allowance
Self-heating allowanceAllow 3.3 K per 1,000 rpm when designing the operating temperature range
Rotor moment of inertia40 gcm²
Bearing lifetime3.6 × 10^10 revolutions
Angular acceleration≤500,000 rad/s²
IP ratingIP65 on housing and shaft sides; IEC 60529
Operating temperature−40 to +100 °C with stationary cable; −30 to +100 °C with flexible cable; account for speed-dependent self-heating
Storage temperature−40 to +100 °C, without packaging
Relative humidity90%, condensation not permitted
Shock resistance70 g, 6 ms; EN 60068-2-27
Vibration resistance30 g, 10–2,000 Hz; EN 60068-2-6
EMCEN 61000-6-2 and EN 61000-6-4
MTTFD300 years; EN ISO 13849-1. Standard product, not a safety component; nominal component load, average ambient +40 °C, 8,760 h/year, all electronic failures considered hazardous
Power consumption≤0.5 W without load
Reverse-polarity protectionProvided
Output short-circuit protectionOpposite another channel, supply US or GND for a maximum of 30 s
Permissible static movement±0.3 mm radial; ±0.5 mm axial
Permissible dynamic movement±0.1 mm radial; ±0.2 mm axial
Cable routingUniversal outlet supports radial or axial cable routing without bending at the outlet
Cable diameter5.6 ±0.2 mm; bend radius 30 mm
Wire assignmentWH=A; BN=complement A; PK=B; BK=complement B; VT=Z; YE=complement Z; BU=GND; RD=+US
Physical Weight (kg)0.2

Industrial Applications

1. Tracking relative angular movement at a rotary station

A rotary station can couple shaft movement to the encoder and feed its A/B signals to an external counter with a compatible HTL / push-pull input. The controller accumulates increments from an established machine reference, using 512 pulses per revolution as the scale. The separate Z signal provides a once-per-revolution reference event, while the external controller maintains the position count.

Problem Solved

Incremental A/B movement and a separate revolution reference give external control a basis for tracking relative station angle and distinguishing successive rotations from an established machine reference.

Relative angular position A/B counting Revolution reference

2. Measuring material feed through a driven roller

A feed mechanism can couple the encoder to its roller drive and count increments during a commanded material advance. External feed logic converts the 512 pulses per revolution through the actual roller circumference and transmission ratio. Commissioning establishes the relationship between shaft rotation and material travel, including any slip, and checks the chosen counting input against the encoder output-frequency limit.

Problem Solved

A counted rotation interval provides external feed logic with a repeatable movement reference, helping compare commanded and observed feed using the installed roller and transmission geometry.

Feed increment Roller travel External length calculation

3. Monitoring drive speed from pulse frequency

A driven mechanism can send the encoder pulse train to an external frequency-measuring input. The controller relates pulses per time interval to the documented pulses per revolution and compares the resulting rotational-speed feedback with its process setpoint. The installation accounts for both the mechanical speed rating and electrical output-frequency limit, together with the specified speed-dependent self-heating allowance.

Problem Solved

Pulse frequency gives external machine control a measured speed reference, helping identify changes in drive rotation during the process using the encoder’s documented pulse scale.

Rotational speed External frequency input Thermal allowance
Select your currency